Estimate recorded rocket apogee
Fit measured apogee from the Rocket Flight Database using the saved Neural Designer model. This small approximation example has 25 flight records and five held-out testing rows.
1. Industrial challenge
Flight analysts can compare measured apogee with a small empirical model and inspect where errors occur. The example replaces the former mission-success classifier with a continuous-output task.
Continuous outcome
Estimate apogee in the source unit of feet.
Small-sample review
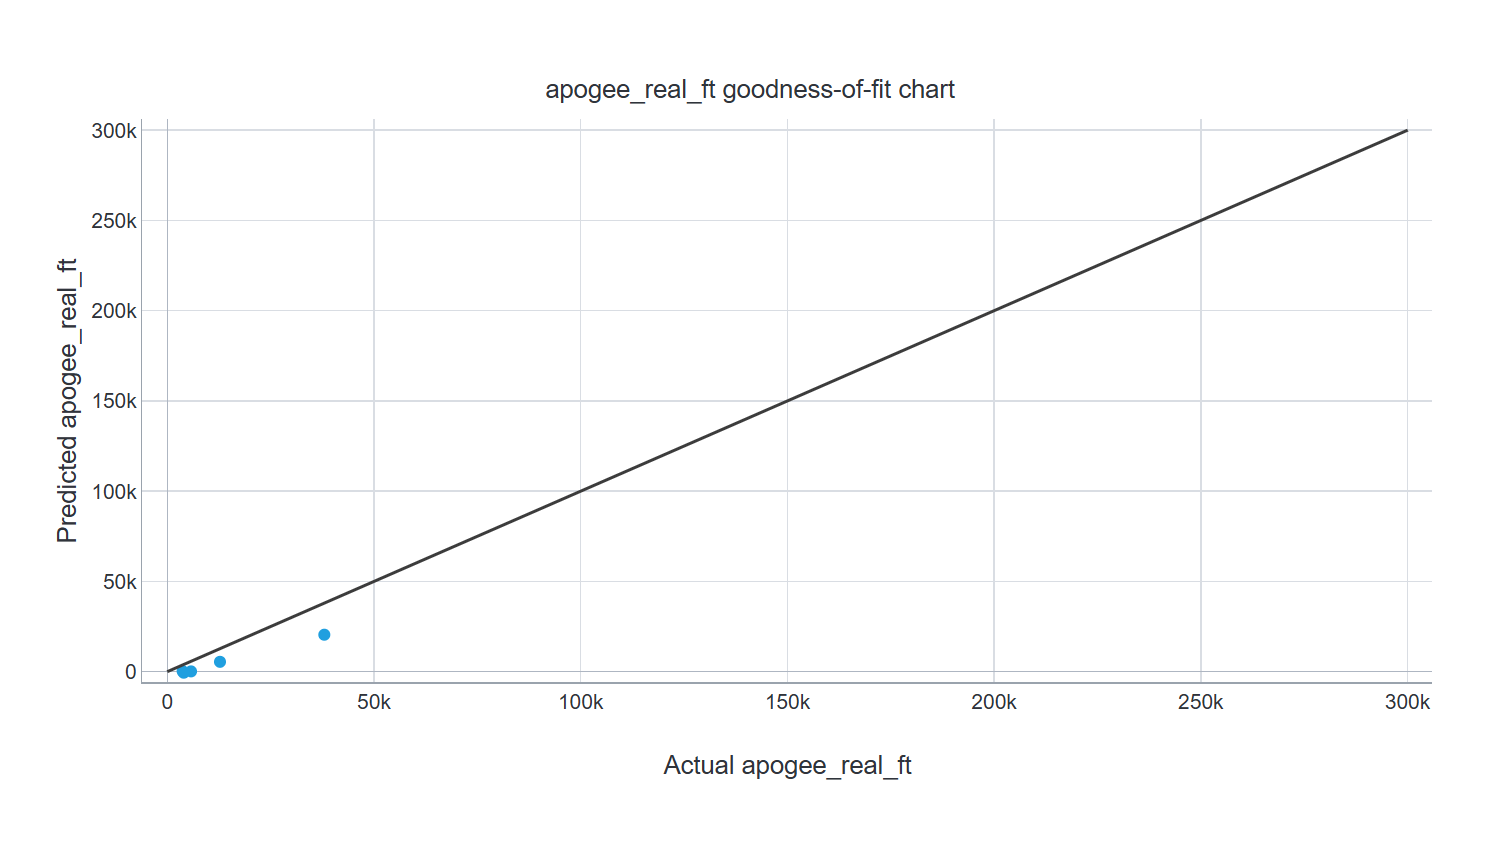
Inspect every held-out prediction.
Availability timing
Verify when each flight descriptor becomes available.
2. Data set
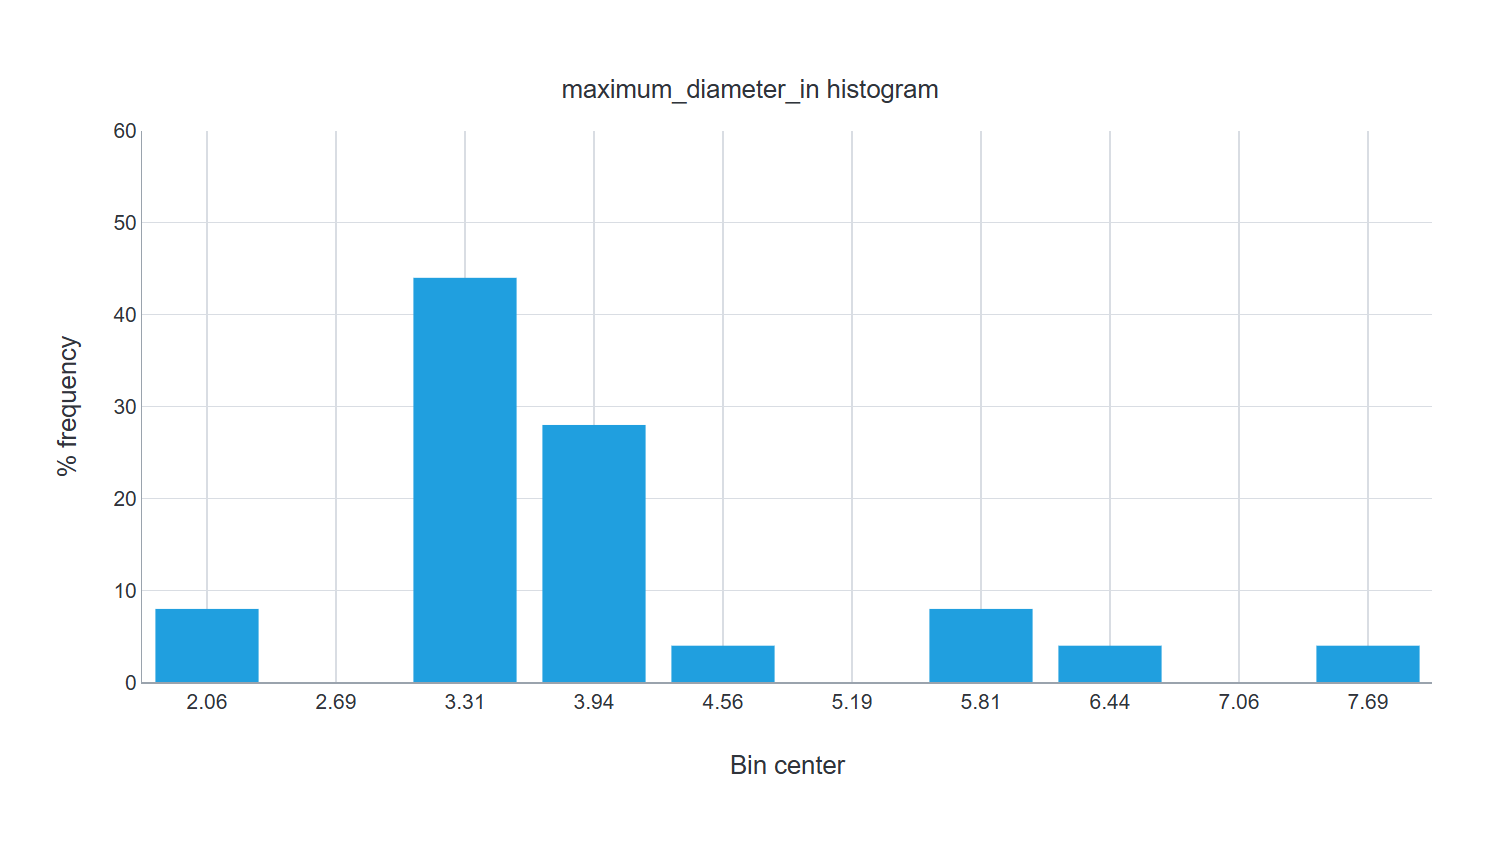
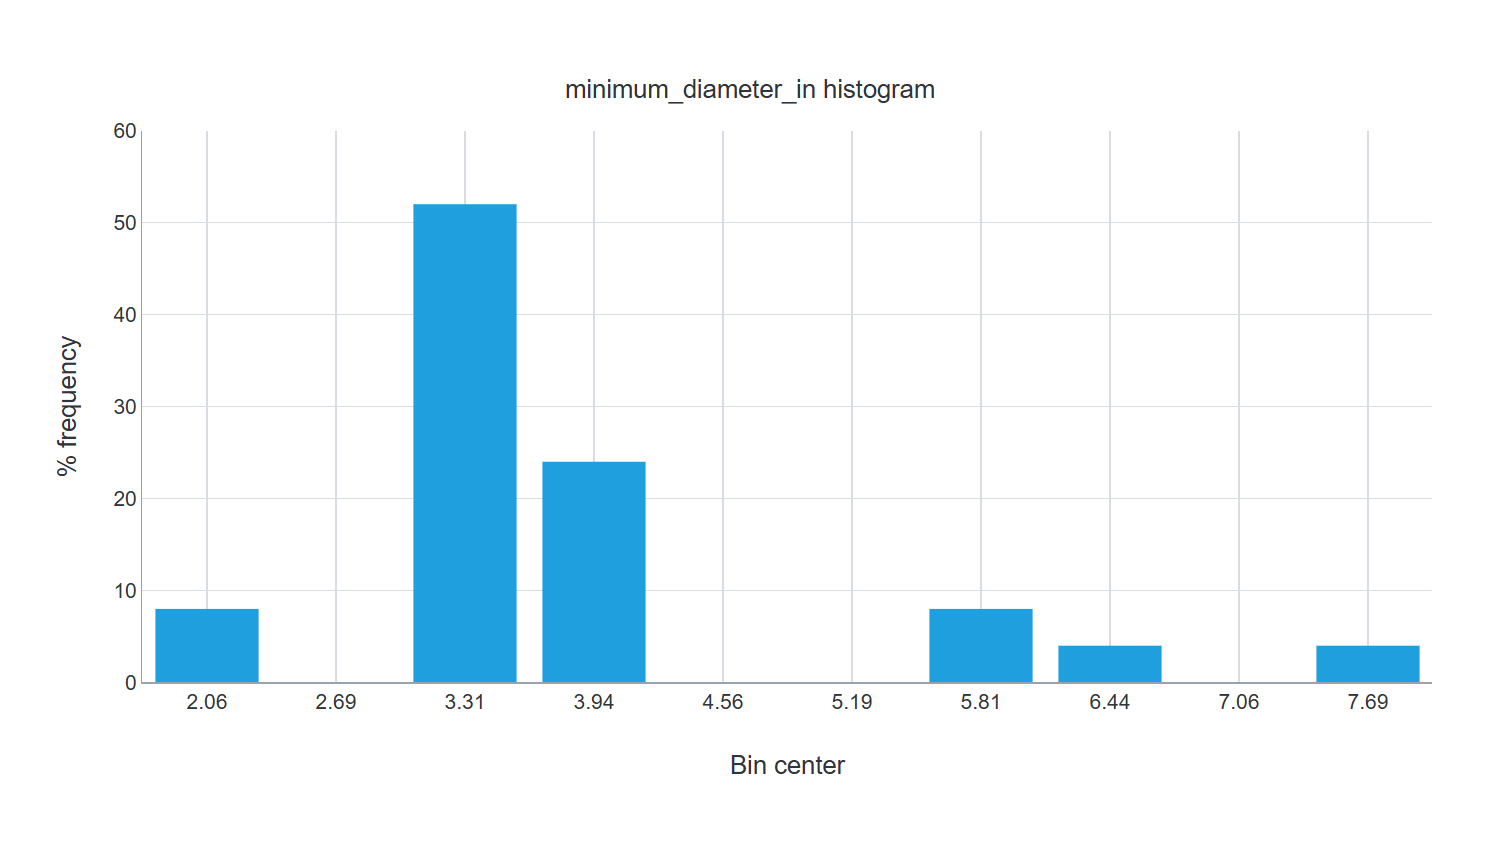
The derived CSV retains motor, maximum and minimum diameter in inches, peak Mach number, launch-site altitude in feet and flight-data type, with apogee_real_ft as the target. Categorical expansion produces eight model inputs.
Source: Rocket Flight Database. Dataset license: CC-BY-4.0. The downloadable ZIP includes the adapted data and attribution notices.
| Dataset measure | Saved value |
|---|---|
| Analysis unit | flight record |
| Records | 25 |
| Raw variables | 6 |
| Encoded model inputs | 8 |
| Model outputs | 1 |
| Training roles | 15 |
| Validation / selection roles | 5 |
| Testing roles | 5 |
| Unused roles | 0 |
| Field | Role | Type | Categories |
|---|---|---|---|
| maximum_diameter_in | Input | Numeric | |
| minimum_diameter_in | Input | Numeric | |
| peak_mach | Input | Numeric | |
| launch_site_alt_ft | Input | Numeric | |
| flight_data_type | Input | Categorical | Barometric Altimeter, GPS, Integrated Accelerometer, Optical Track |
| apogee_real_ft | Target | Numeric |
3. Model
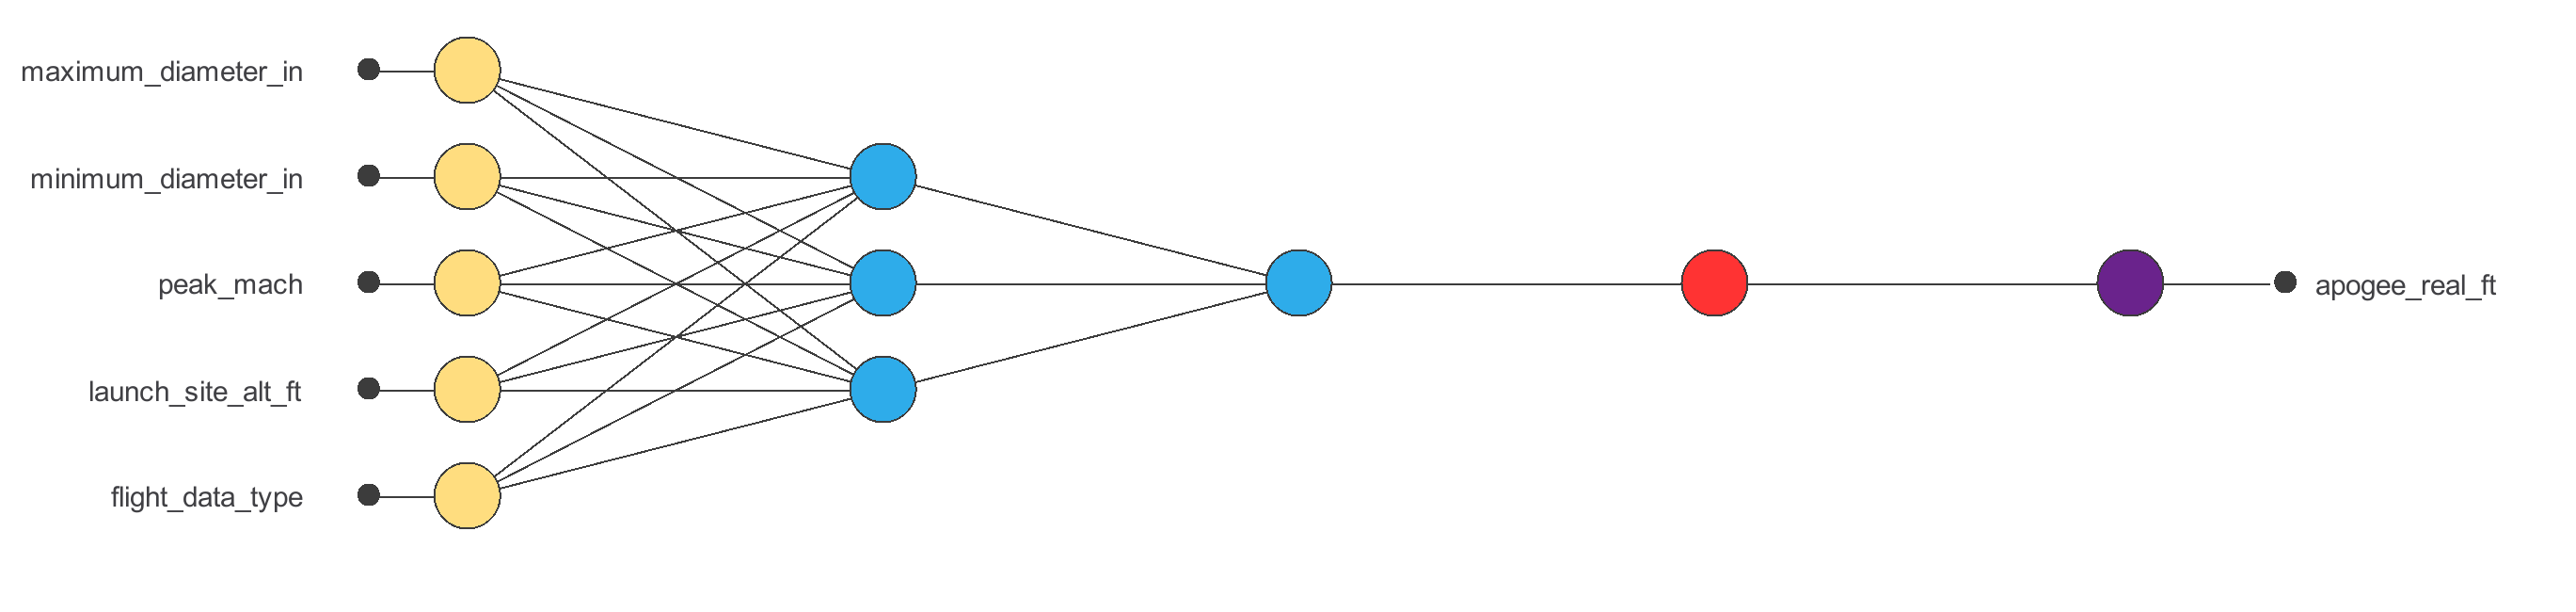
The model has 8 encoded inputs and 1 outputs. No architecture-selection experiment is recorded in this project. The diagram shows the topology used by the saved model.
| Layer | Input shape | Output shape | Activation |
|---|---|---|---|
| Scaling | 8 | 8 | |
| Dense | 8 | 3 | Tanh |
| Dense | 3 | 1 | Identity |
| Unscaling | 1 | 1 | |
| Clamping | 1 | 1 |
4. Training strategy
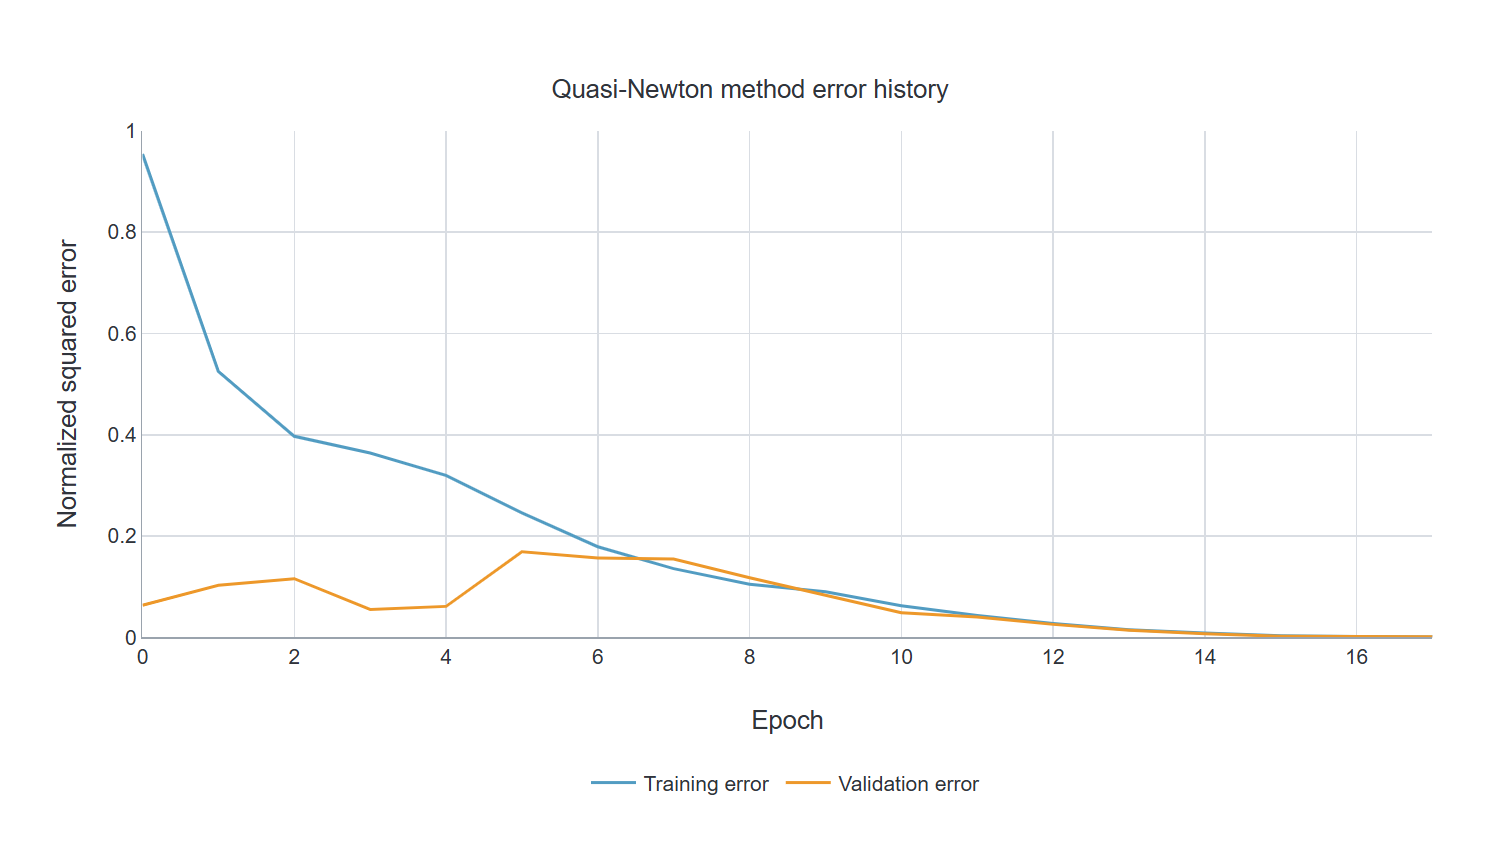
The saved training configuration uses QuasiNewton with NormalizedSquaredError.
Quasi-Newton method results
| Measure | Value |
|---|---|
| Epochs number | 18 |
| Elapsed time | 00:00:00 |
| Stopping criterion | Loss goal |
| Training error | 0.002 |
| Validation error | 0.001 |
5. Model selection
No model selection experiment is recorded for this version. The validation subset guides fitting where a training report is present; it is distinct from the held-out test rows.
6. Testing analysis
The figures and tables below refer to the current project’s saved testing analysis. The subset uses testing role 2; it contains 5 source records.
apogee_real_ft goodness-of-fit parameters
| Measure | Value |
|---|---|
| Determination | 0.997 |
7. Model deployment
Open the downloaded project in Neural Designer, inspect the dataset roles and preprocessing, then review the saved task report. Use the same input schema and category order when calculating outputs. The ZIP contains the exact current .nd, its source data and the applicable dataset notices.
Workflow: source measurements → schema and availability checks → model output → domain review. Keep model versions, validation evidence and incoming-data monitoring together.
8. Scope and limitations
Five test flights provide very limited evidence. Peak Mach and other flight-condition descriptors must be available at the time of inference; this saved model is not necessarily a pre-launch predictor. Assess transfer across motors, sites and flight regimes before use.
References
- Rocket Flight Database. Aidan Yu. 10.5281/zenodo.19976139
- Dataset terms: Creative Commons Attribution 4.0 International. Full attribution and transformations are included in
LICENSES/DATASET-LICENSE.txt. - Current Neural Designer project and saved task report, snapshot 6 October 2026.